








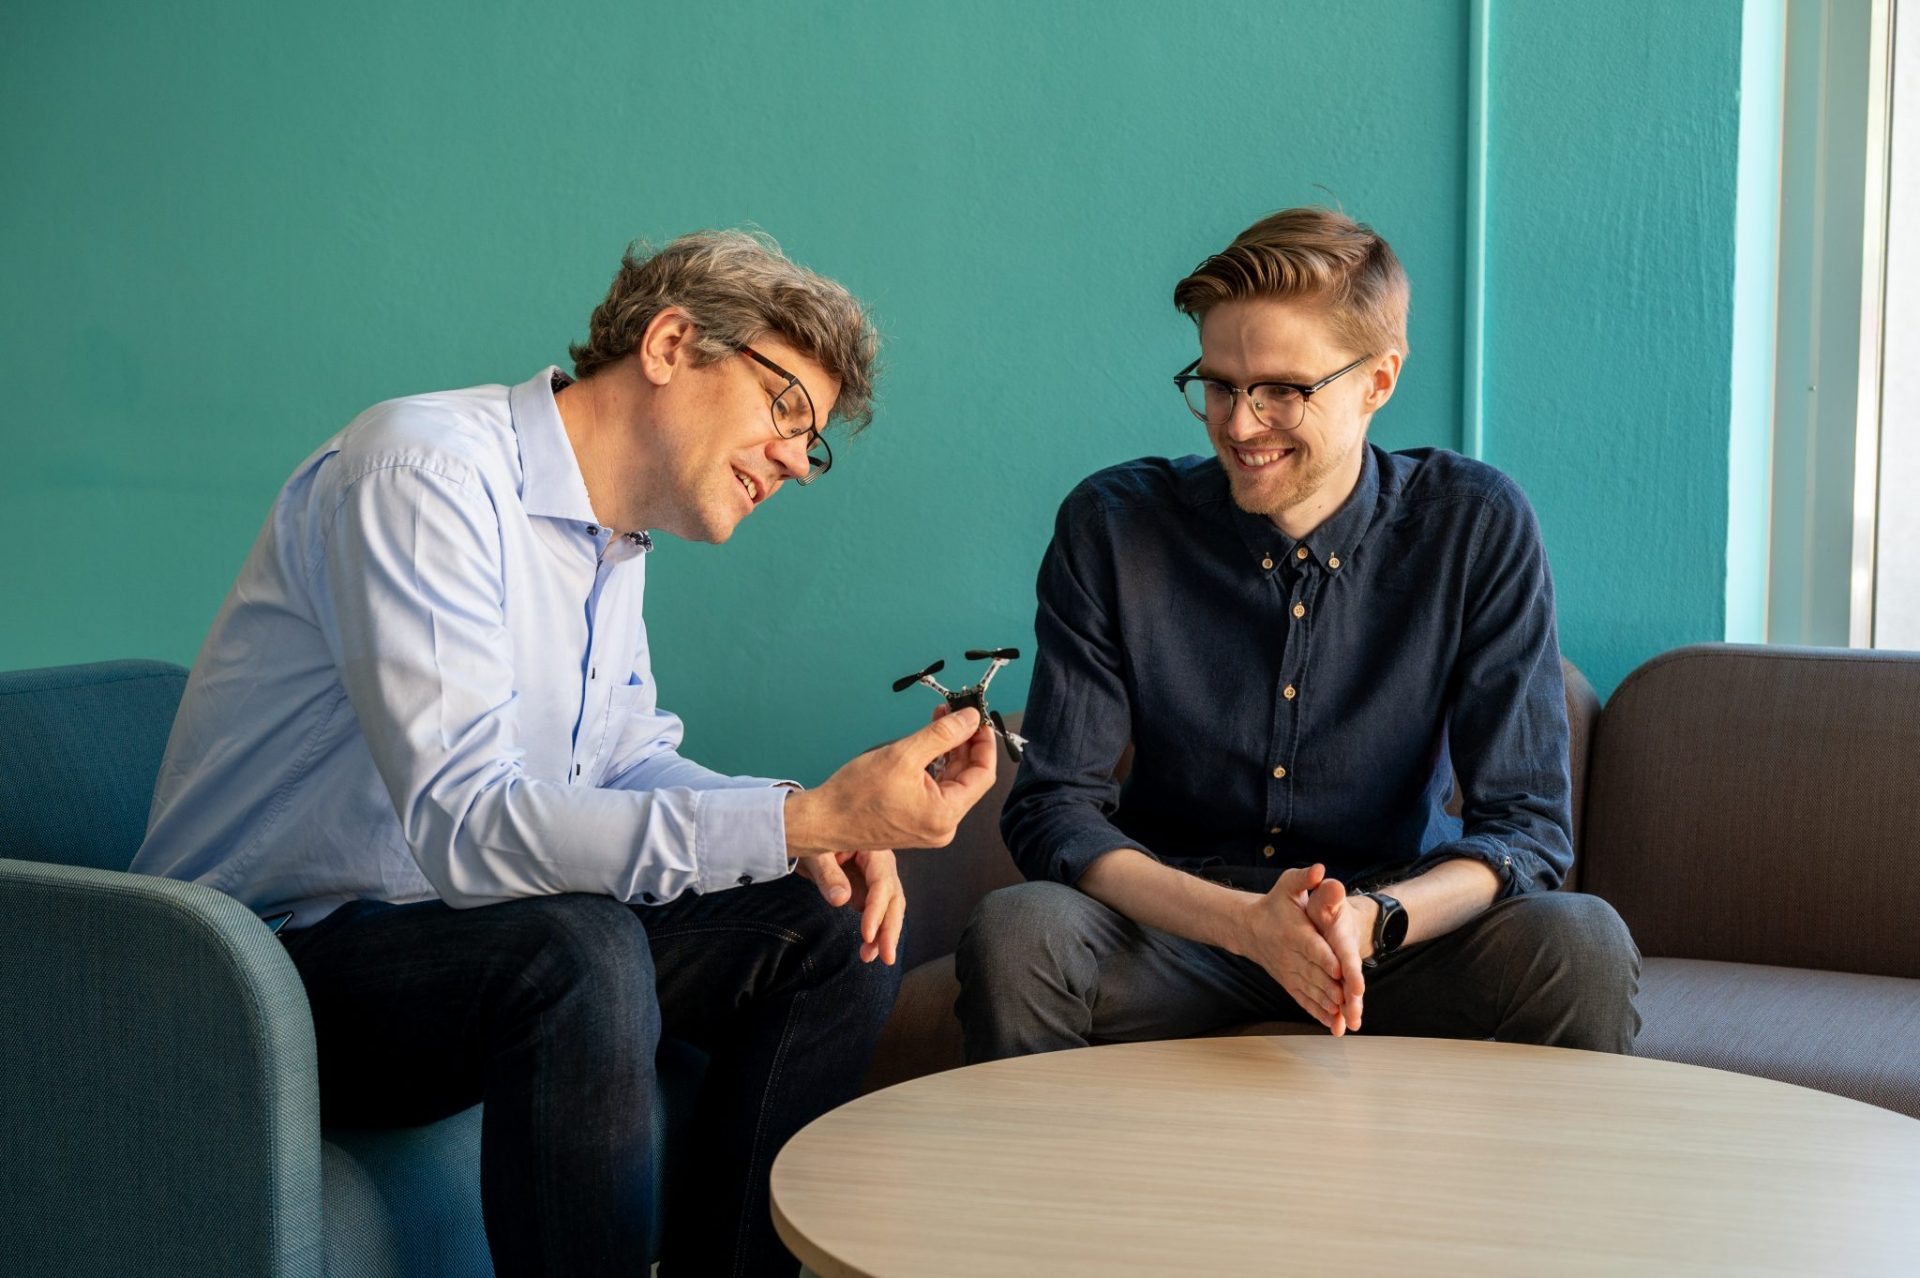
Research by Daniel Axehill and Daniel Arnström contributes to Sony AI’s table tennis robot Ace, recently featured on the cover of Nature. Their work helps the robot make control decisions within milliseconds, a key capability in fast-moving physical AI systems. Axehill is WASP Graduate School Director and professor in automatic control at Linköping University. Arnström is a WASP supervisor and senior researcher at Ericsson Research.
The autonomous robot system Ace, developed by Sony AI, combines high-speed perception, learning-based methods, optimization-based control, and advanced robotic hardware to track, predict, and return a table tennis ball in real time. For Axehill and Arnström’s research, the system offers an example of how their optimization methods can be used in a state-of-the-art, physical AI application.
A central challenge in the system is the ability to make control decisions within milliseconds. Axehill and Arnström’s research contributes to this capability through an optimization algorithm and its implementation in the open-source software DAQP, which helps systems make fast optimization decisions under tight time constraints.
The research behind DAQP focuses on efficient optimization for embedded systems. In Ace, it helps connect the robot’s decision-making to precise, real-time physical movement.
“Telling which solver is currently the fastest varies from day to day and from application to application, but we can at least safely say that the combination of the algorithm and its implementation is one of the fastest available QP optimization software packages for these types of problems today,” says Daniel Axehill.
Model Predictive Control helps translate decisions from the robot’s reinforcement learning layer into physical movements. This allows the robot to move quickly, accurately, and safely. DAQP supports this process by solving 1,000 optimization problems per second, while taking constraints into account to protect components such as the electrical motors. The solver is also used for near-time-optimal control problems, including quickly retracting the paddle from an executed stroke back to its ready position.
According to Axehill, DAQP has also shown strong performance in other demanding real-time control settings, including nano-drone control at 500 Hz and autonomous trucks at Scania.
“The key result is that the optimization problem has been reformulated, the numerical linear algebra has been developed to be highly efficient for the application, and the result has been packaged in efficient software,” says Daniel Arnström.
Axehill’s and Arnström’s research, initially funded by VR, with the purpose to guarantee, a priori, that a QP optimization algorithm will always find a solution with certain properties is now being further developed in two ongoing WASP projects; “Next-generation fast real-time certified optimization algorithms for MPC” and “Reliable High-Performance MPC Targeting Nano Platforms”.
DAQP shows that a solver with this type of reliability guarantees can also be very fast, although the certification process can require substantial offline computing. The current WASP research explores how these reliability guarantees can be scaled to larger, practically relevant applications. High-performance computing is one possible direction, alongside several other approaches currently being explored.
Published: September 1st, 2026
[addtoany]
此内容由惯性聚合(RSS阅读器)自动聚合整理,仅供阅读参考。 原文来自 — 版权归原作者所有。