







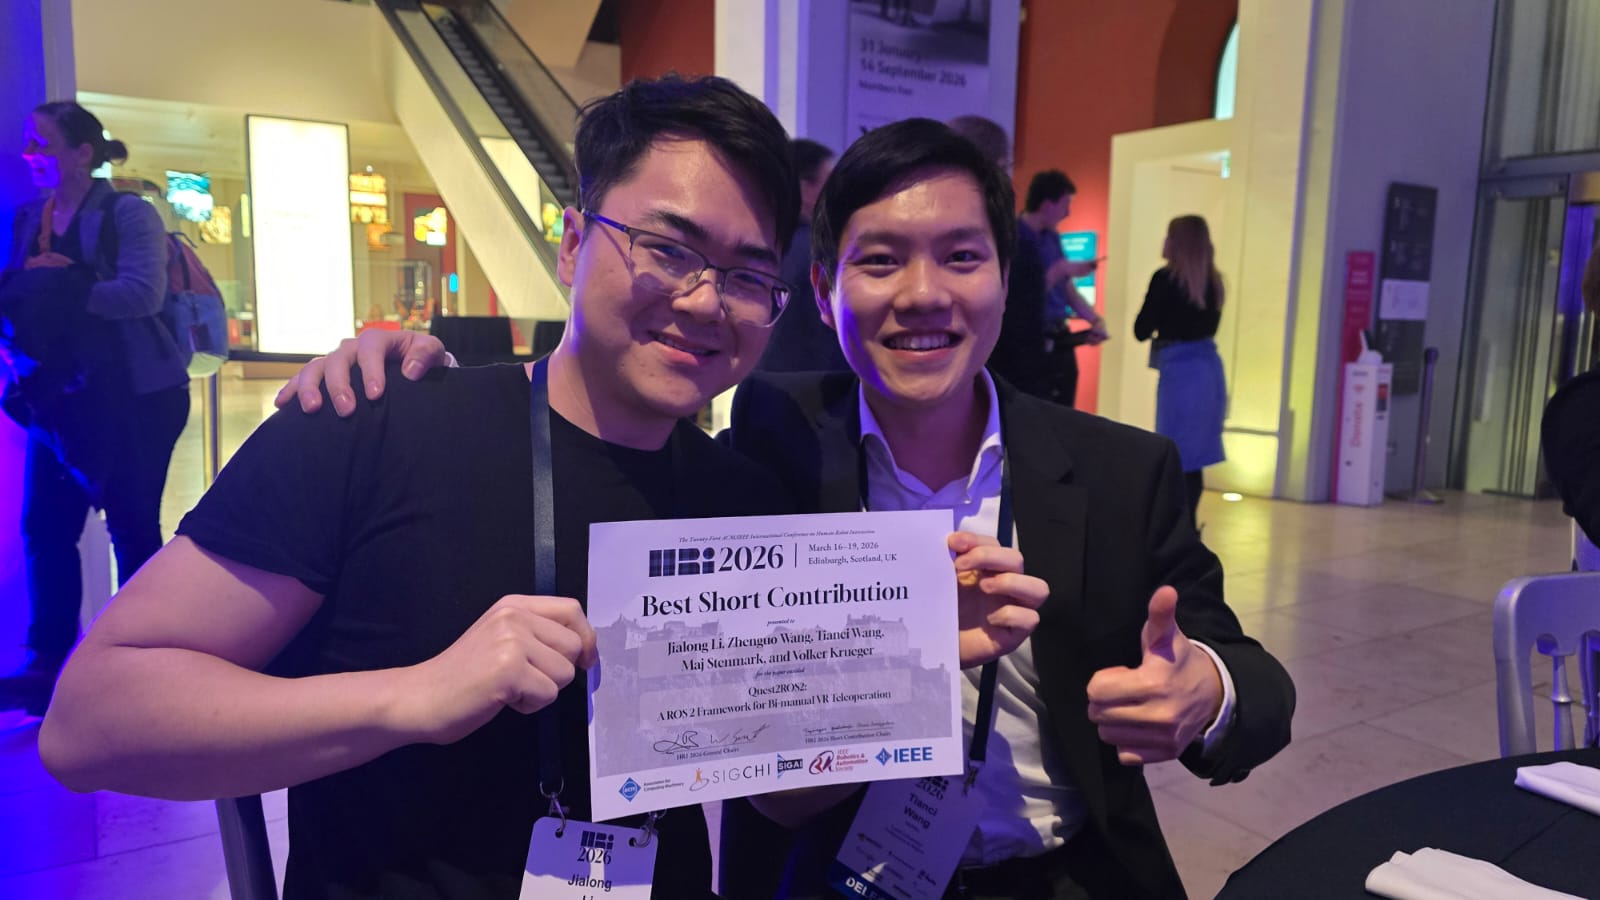
From left: Jialong Li, WASP PhD student, Lund University together with Tianci Wang, third author of the paper.
WASP PhD student Jialong Li at Lund University has been awarded Best Paper in the Short Contribution track at the ACM IEEE International Conference on Human Robot Interaction 2026, one of the world’s premier venues for research at the intersection of humans and intelligent machines.
His awarded work, Quest2ROS2, introduces a new open‑source teleoperation framework designed specifically for bi‑manual robot learning in ROS2, addressing a gap that has long challenged robotics researchers.
“In robotics, especially in recent years, there has been a shift toward data driven approaches inspired by advances in language and computer vision,” says Jialong Li. “But collecting robotic data is much harder than collecting image or text data, which makes teleoperation increasingly important.”
When starting his PhD, he identified a clear gap in existing tools. “I could not find a good open-source teleoperation system that met my needs,” he explains. “Most available frameworks were designed for single arm robots, not built in ROS2, or difficult to get started with.”
To address this, he developed Quest2ROS2 by extending earlier work and redesigning it for dual arm robots and modern robotics systems. The result is a flexible and user-friendly framework with a modular structure for easy extension and integration.
“I made design choices such as a decoupled ROS2 structure and added functionality that lets the robot either mirror or directly follow the user’s movements,” he says. “This gives more freedom in how the system can be used.”
Quest2ROS2 builds on earlier work by former WASP PhD student Michael C. Welle at KTH. His work “Quest2ROS: An App to Facilitate Teleoperating Robots”, introduced a system for single arm robot teleoperation using a Meta Quest device in ROS1. Quest2ROS2 extends this foundation to ROS2 and bi manual robots, enabling more advanced and scalable robot learning applications.
By enabling more efficient data collection, the framework contributes to ongoing efforts in robot learning. “I hope this can be a small contribution to the research community working toward more general and capable intelligent robots,” says Jialong Li.
Published: May 22nd, 2026
[addtoany]
此内容由惯性聚合(RSS阅读器)自动聚合整理,仅供阅读参考。 原文来自 — 版权归原作者所有。