







News |
By Brian Tristam Williams
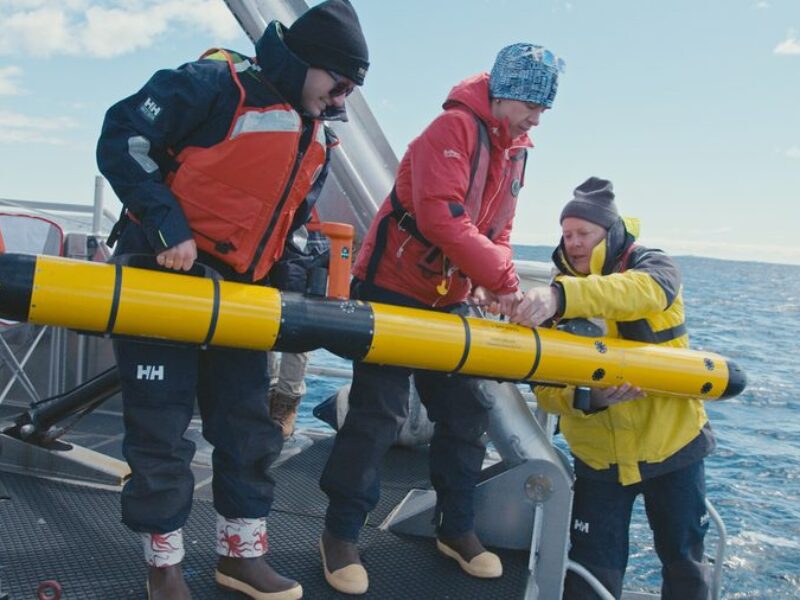
MIT Lincoln Laboratory is developing a human-machine system that pairs divers with autonomous underwater vehicles for tasks such as subsea cable inspection, search and rescue, harbour entry and countermine work. The idea is straightforward enough: let the robot do the computation, endurance and rapid movement, while the diver handles dexterous work and the kind of judgement that still matters when underwater scenes are messy, degraded or simply odd.
One of the clearest use cases is fault-finding on undersea power or telecoms links. Rather than hauling up a cable or relying entirely on a remotely operated vehicle, the MIT team wants an AUV to map the line, identify the likely problem area and guide a diver to the right place. That lands neatly in a wider infrastructure context, as previously reported by eeNews Europe when the UK warned of growing undersea cable security risks.
The hard bit is not putting a diver and a vehicle in the same patch of water. It is making them genuinely useful to each other in dark, silty, current-driven conditions with very little bandwidth. In MIT’s report on the project, principal investigator Madeline Miller says divers and AUVs generally do not team underwater today, largely because the missions that still need people also tend to require manipulation that robots cannot yet match.
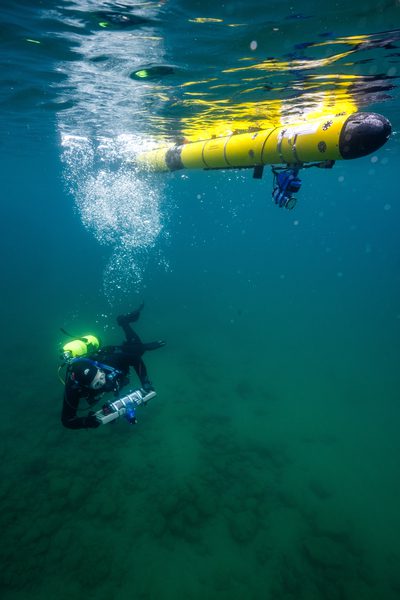
A diver and an autonomous underwater vehicle operate together during underwater testing related to MIT’s human-machine teaming research. Photo: Tim Briggs/Lincoln Laboratory
The perception problem is equally awkward. Cameras fail in darkness and turbidity, while sonar produces shape-heavy imagery that is harder to interpret and much less richly labelled than optical data. MIT’s answer is an onboard classifier that can fuse optical and sonar inputs, then ask the diver for help when confidence is low. That human feedback loop, however, has to run through an acoustic modem, where sending a full uncompressed image can take tens of minutes.
The navigation side builds on earlier MIT work rather than appearing from nowhere. A 2022 MIT-WHOI thesis by Jesse Pelletier described subsurface diver-AUV teaming based on acoustic communication and commercial AUV navigation, without requiring exact diver speeds or ocean current data. In field tests using kayaks as proxies, that work reported an average online end-point error of 4.53 m over 400 m transits.
Lincoln Laboratory has since pushed the concept into rougher, more realistic conditions, adding more sensing on the diver side and packaging the system around mostly commercial off-the-shelf hardware. The payload combines sonar, optical sensing, an acoustic modem and onboard compute, and has been tested around coastal New England and with divers at Michigan Tech’s Great Lakes Research Center.
For now, this is a research and transition story rather than a product launch. But it is a practical one. MIT is trying to compress just enough information to be useful underwater, run perception locally on the vehicle, and fit the package into platforms already used in the field. If that works, underwater robot teaming could become a more realistic tool for infrastructure inspection and repair, not just a neat demo for calm-water trials.
 If you enjoyed this article, you will like the following ones: don't miss them by subscribing to :
此内容由惯性聚合(RSS阅读器)自动聚合整理,仅供阅读参考。 原文来自 — 版权归原作者所有。