
惯性聚合 高效追踪和阅读你感兴趣的博客、新闻、科技资讯
阅读原文 在惯性聚合中打开

推荐订阅源

S
SegmentFault 最新的问题
博客园 - 三生石上(FineUI控件)
WordPress大学
WordPress大学
博客园 - 【当耐特】
月光博客
月光博客
Vercel News
Vercel News
D
Docker
I
InfoQ
Apple Machine Learning Research
博客园 - 叶小钗
MongoDB | Blog
MongoDB | Blog
GbyAI
GbyAI
有赞技术团队
有赞技术团队
雷峰网
雷峰网
博客园 - 聂微东
小众软件
小众软件
Y
Y Combinator Blog
腾讯CDC
L
LangChain Blog
The GitHub Blog
The GitHub Blog
宝玉的分享
宝玉的分享
Stack Overflow Blog
Stack Overflow Blog
大猫的无限游戏
大猫的无限游戏
T
The Blog of Author Tim Ferriss

Lobsters

CIFSwitch: a non-universal Linux local root vulnerability RIPE NCC session fixation: poaching logins with an Atlas probe GNOME 2.20 but its Web Components Agentic Search for Context Engineering – Leonie Monigatti Garnix is shutting down [not OC] akashina.tngl.sh/jjc Concerning Emacs (and Jazz) Nitpicking the shell history scene in ‘Tron: Legacy’ What's cooking on SourceHut? Q2 2026 The tenth OpenPGP email summit Package managers that package package managers Clojure on Fennel part three: parsing WordPress at 23 Finding Miscompiles for Fun, Not Profit GitHub - creusot-rs/creusot: Creusot helps you prove your Rust code is correct. Announcing Rust 1.96.0 | Rust Blog A Love Letter to Neovim sqlite AGENTS.md Am I a Bad Friend? CSS vs. JavaScript • Josh W. Comeau Erlang Ecosystem Foundation - Supporting the BEAM community A brief note about slot access cost in Common Lisp Keyboard latency probe Rethinking the GNOME clipboard issues Back to the Building Blocks’ Building Blocks Tech Notes: Theseus: translating win32 to wasm Fast is better than slow Content-addressed Rust builds (or, what kache actually caches) Intent to Prototype: Embedding API Canada’s Bill C-22 and the security cost of collecting more data
Building an Open-Source Robot Vacuum — Meet oomwoo - Make...
Ilia O. · 2026-06-28 · via Lobsters

Today I’m kicking off my most ambitious Maker’s Pet project yet: oomwoo, an open-source home robot vacuum that you can build yourself. Open hardware, open firmware, open software — and built in public, from the first commit.

No cloud required. No vendor lock-in. It maps your home with an affordable 2D LiDAR and navigates on its own, runs locally, and integrates natively with Home Assistant. If you’re into Raspberry Pi, ROS 2, 3D printing, or just the idea of owning a vacuum you fully understand and control — this one’s for you.

About the name: “oomwoo” is a rotational ambigram — it reads the same flipped 180°, just like the robot itself roaming your floor in every direction.
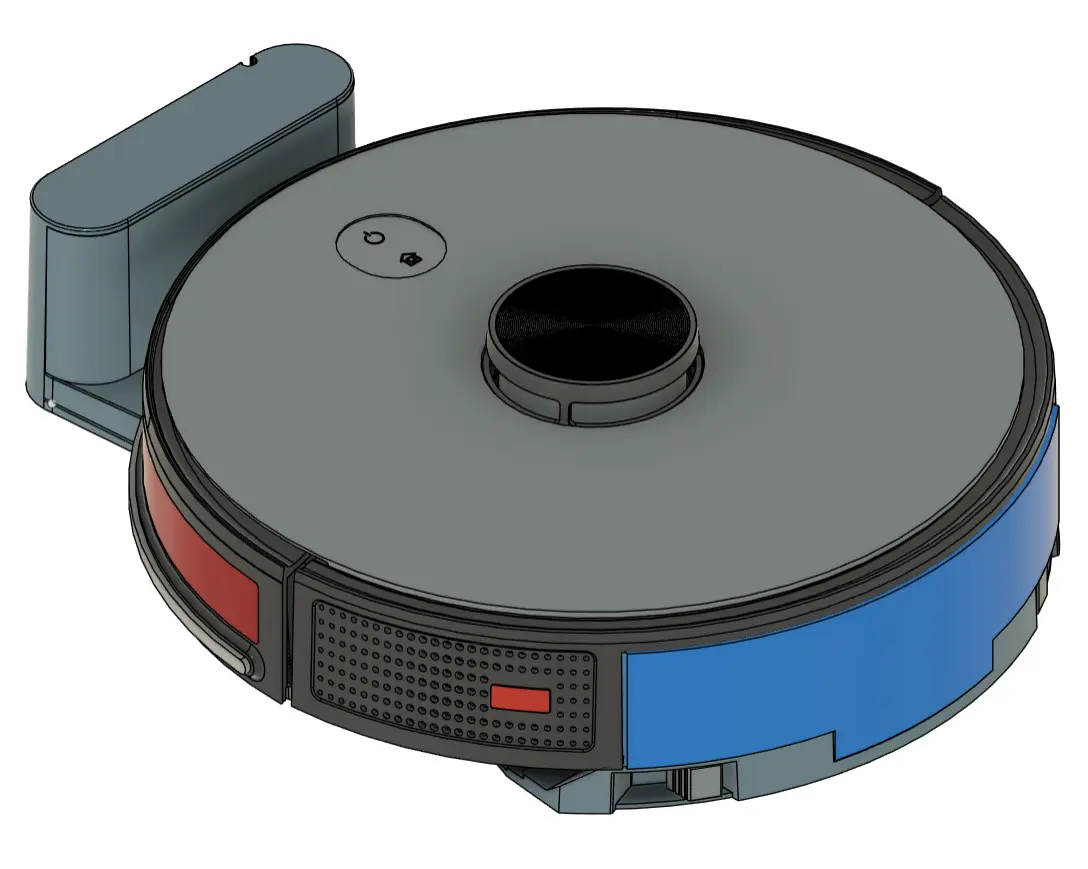
oomwoo open-source robot vacuum reference design, top view
Reference design — roughly how the finished oomwoo will look.

What oomwoo is

oomwoo is a build-it-yourself robot vacuum designed for the maker community:

  • Affordable and fully open — hardware, software, and firmware
  • 2D LiDAR mapping and autonomous navigation with ROS 2 / Nav2
  • Native Home Assistant integration for local control
  • 3D-printable, documented, hackable chassis
  • Local-first — no cloud needed for everyday cleaning, ever
  • Home-appliance quality — not a throwaway build
  • Step-by-step, zero-to-hero build instructions, with a complete bill of materials so you can source every part yourself

Optional extras — cloud features, and eventually an app store of ROS 2 apps to customize how your vacuum behaves — will layer on top. But the core promise never changes: the vacuum always works cloud-free and local, out of the box.
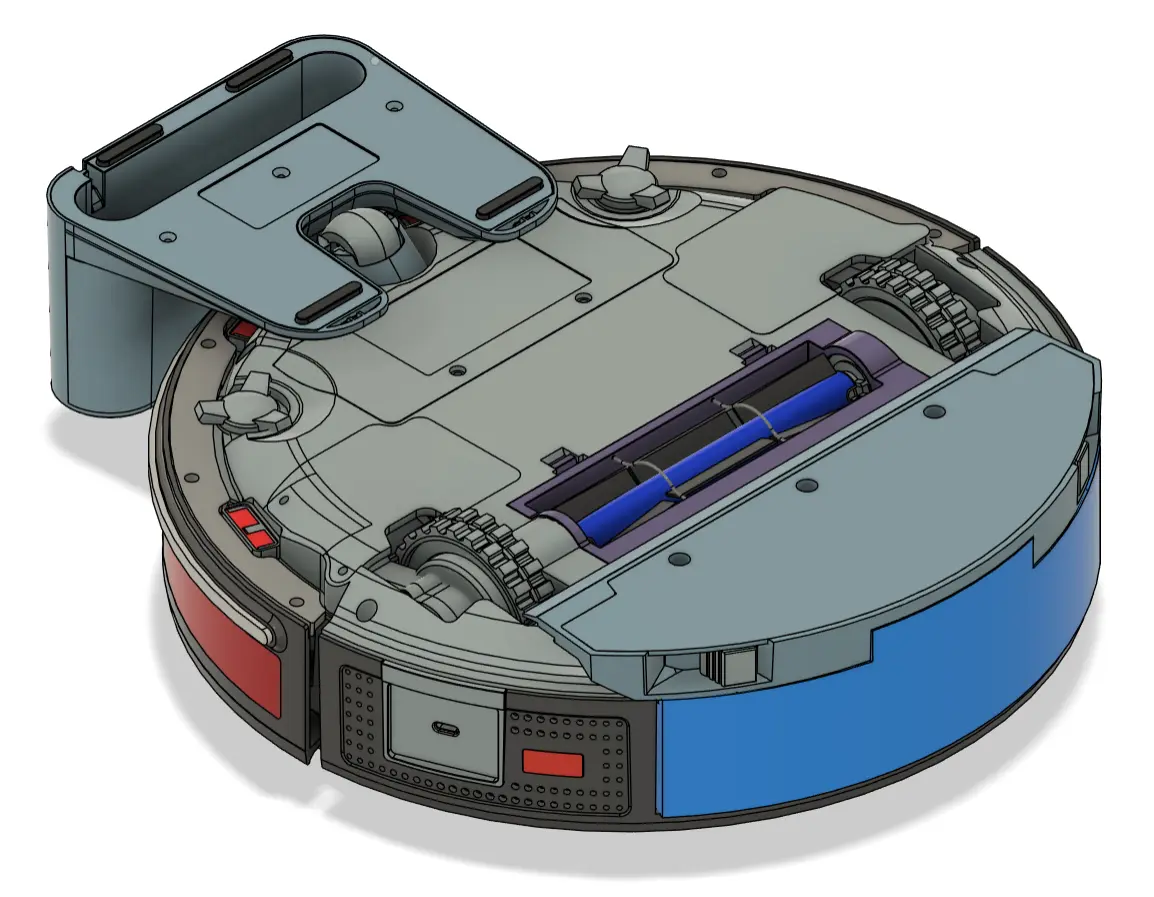
oomwoo open-source robot vacuum reference design, bottom view
The underside of the reference design.

Where the project is today

This is genuinely early — and that’s the point of building in public. The first milestone (v0) is a bare-bones, working build:

  • 3D-printed chassis
  • ROS 2 Gazebo simulation
  • LiDAR with manual SLAM
  • ROS 2 on a Raspberry Pi 5 and/or ESP32 running micro-ROS (final architecture still being decided)

The open-source deliverables I’m working toward: bill of materials, 3D-printable files, ROS 2 packages, firmware, a motor-driver and sensor PCB, full build / bringup / troubleshooting docs, and demo videos.
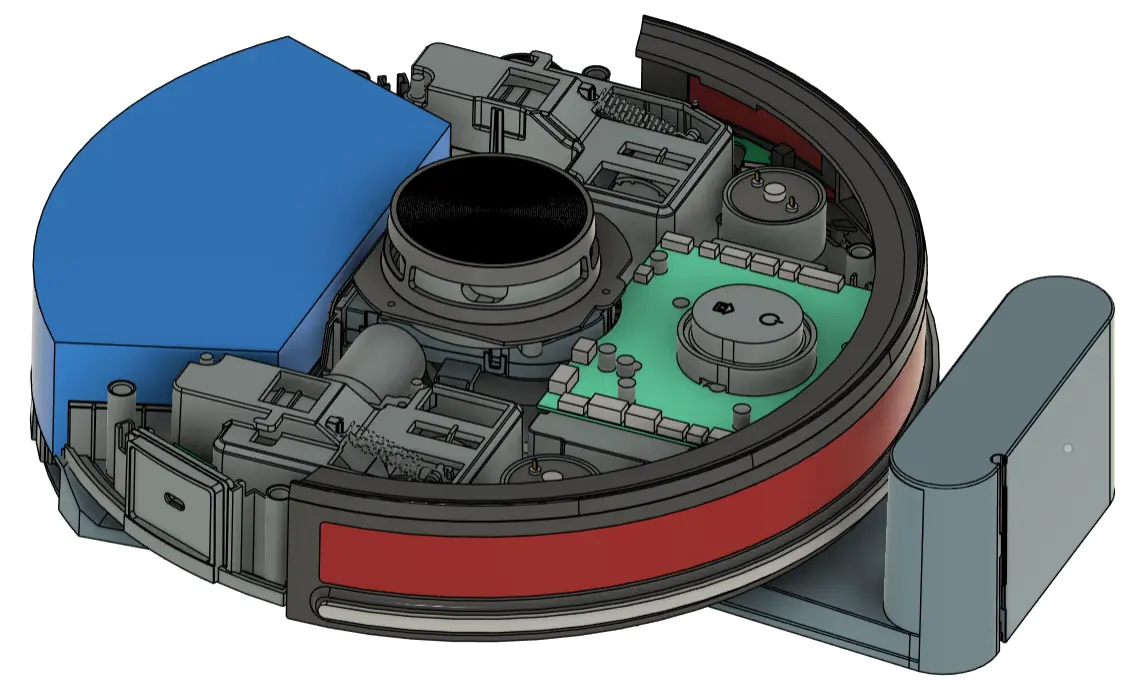
oomwoo open-source robot vacuum with top cover removed, internal layout
Top cover removed — a peek at the internal layout.

Build it with me — massively in parallel

oomwoo is organized so the community can build it in parallel. The robot and its software are split into self-contained modules. You pick whatever module interests you, work on it whenever you want, and submit your work as a pull request. Multiple people can tackle the same module — the best solution surfaces over time.

Modules ready to start right now include:

  • ROS 2 URDF + Gazebo simulation — robot model, TF, bumper, sim
  • First clean — coverage cleaning while SLAM-mapping and exploring
  • Dust bin — design, 3D print, and test
  • Vacuum fan / blower assembly — blower motor, impeller, volute housing

If you’d like to jump in, the GitHub repo has the module list, the architecture doc, and contribution guidelines.

Follow along

I’ll be sharing progress, dead ends, and wins as they happen:

Follow oomwoo build

Open-source robot vacuum community build updates

Parts Kit

Everything about oomwoo stays open — you can source every part yourself. If you’d rather skip the parts hunt, a convenience kit (motors, PCB, brushes, gaskets, LiDAR) will be available here at Maker’s Pet, from the same maker behind this project. The kit is a convenience, never a requirement.